PneuGelSight: Soft Robotic Vision-Based Proprioception and Tactile Sensing
Published in The International Journal of Robotics Research (IJRR), 2025
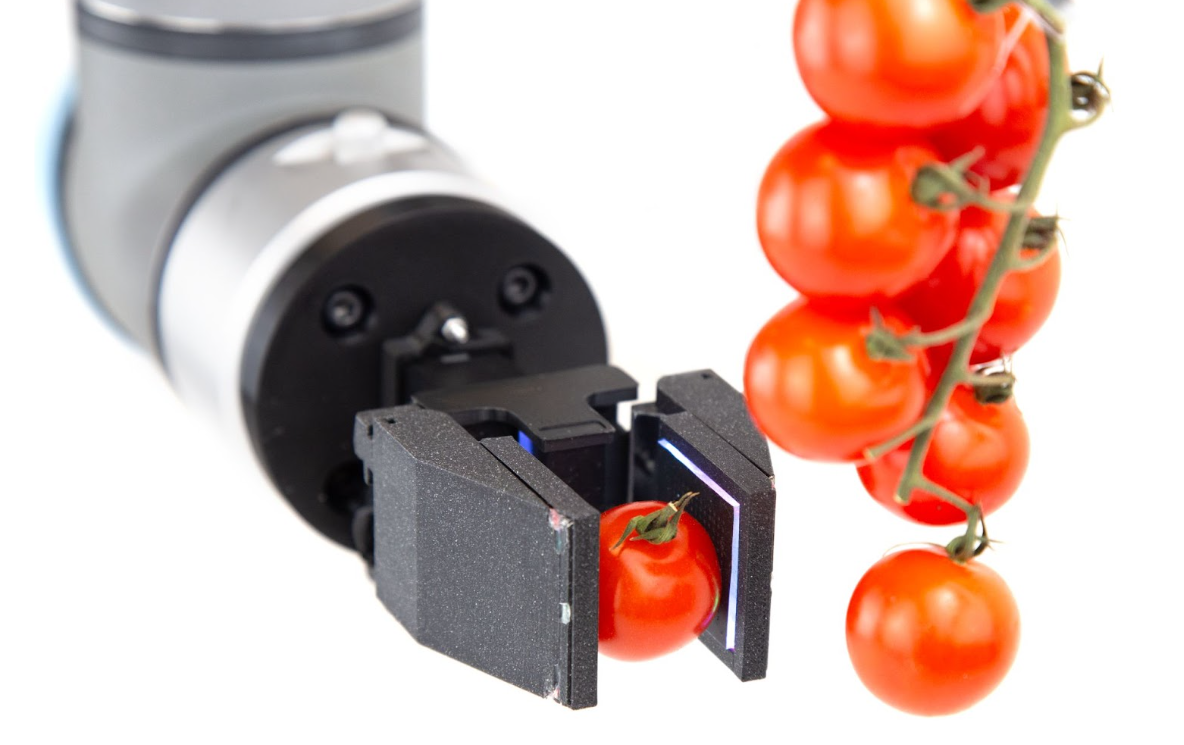
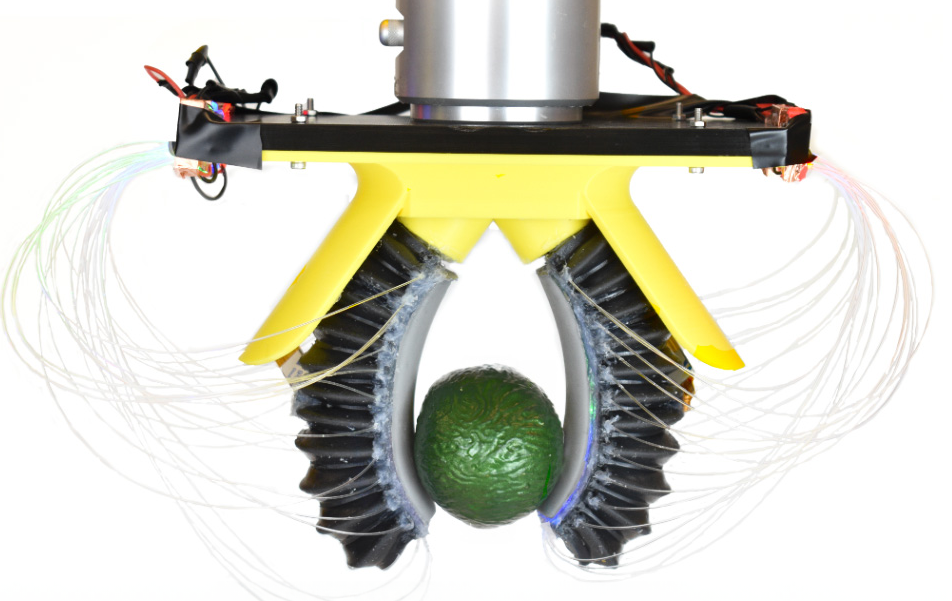
We introduce PneuGelSight, a pneumatic manipulator with integrated vision-based tactile sensing and proprioception. Our pipeline enables accurate optical and dynamic simulation, supporting zero-shot sim-to-real transfer for robust manipulation.
Recommended citation: Ruohan Zhang, Uksang Yoo, Yichen Li, Arpit Agarwal, Wenzhen Yuan. (2025). "PneuGelSight: Soft Robotic Vision-Based Proprioception and Tactile Sensing." The International Journal of Robotics Research (IJRR).
Download Paper