FruitTouch: A Perceptive Gripper for Gentle and Scalable Fruit Harvesting
Published in IEEE Robotics and Automation Letters (RA-L), 2026
Ruohan Zhang, Mohammad Amin Mirzaee, Wenzhen Yuan
Accepted; to appear.
Abstract
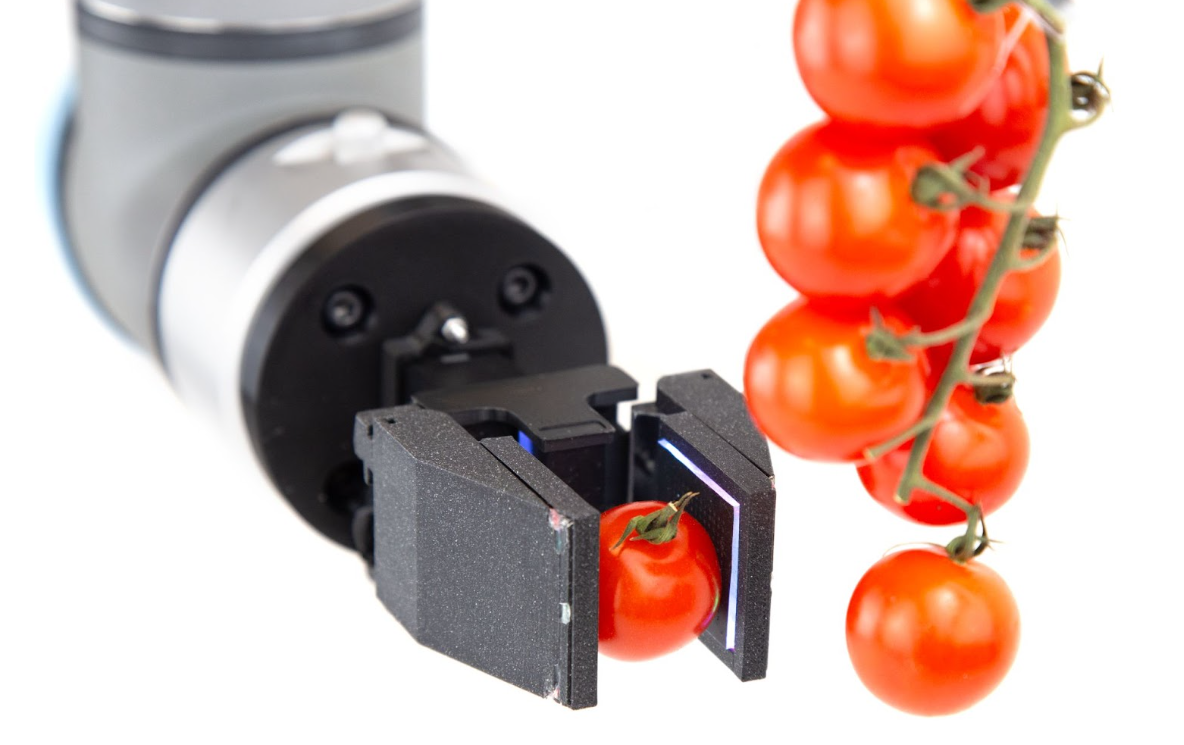
The automation of fruit harvesting has gained increasing significance in response to rising labor shortages. A sensorized gripper is a key component of this process, which must be compact enough for confined spaces, able to stably grasp diverse fruits, and provide reliable feedback on fruit condition for efficient harvesting. To address this need, we propose FruitTouch, a compact gripper that integrates high-resolution, vision-based tactile sensing through an optimized optical design. This configuration accommodates a wide range of fruit sizes while maintaining low cost and mechanical simplicity. Tactile images captured by an embedded camera provide rich information for real-time force estimation, slip detection, and softness prediction. We validate the gripper in real-world cherry tomato harvesting experiments, demonstrating robust grasp stability, effective damage prevention, and adaptability to challenging agricultural conditions.
Citation
@article{zhang2026fruittouch,
  title   = {FruitTouch: A Perceptive Gripper for Gentle and Scalable Fruit Harvesting},
  author  = {Zhang, Ruohan and Mirzaee, Mohammad Amin and Yuan, Wenzhen},
  journal = {IEEE Robotics and Automation Letters},
  year    = {2026}
}
Recommended citation: Ruohan Zhang, Mohammad Amin Mirzaee, Wenzhen Yuan. (2026). "FruitTouch: A Perceptive Gripper for Gentle and Scalable Fruit Harvesting." IEEE Robotics and Automation Letters (RA-L).