FruitTouch: A Perceptive Gripper for Gentle and Scalable Fruit Harvesting
Published in IEEE Robotics and Automation Letters (RA-L), 2026
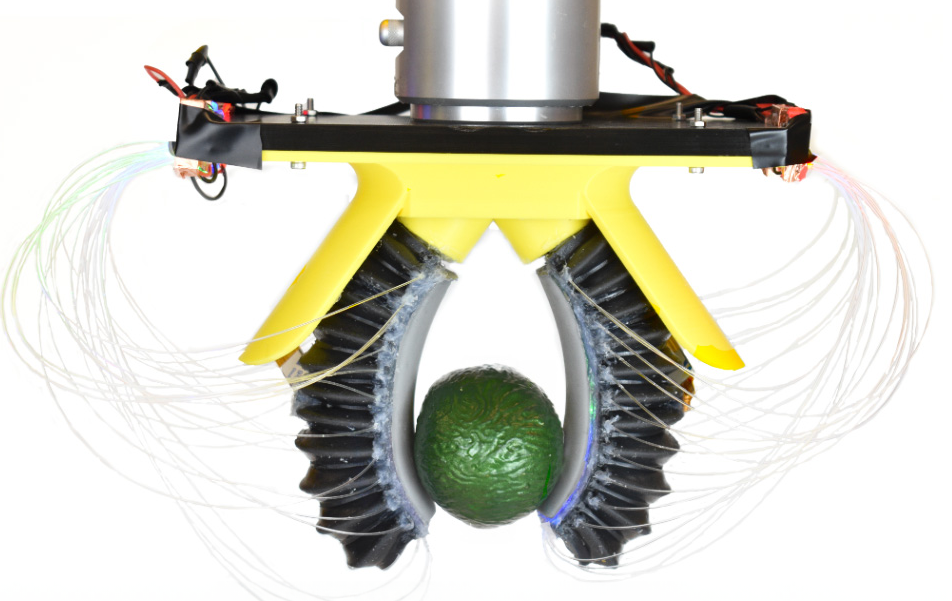
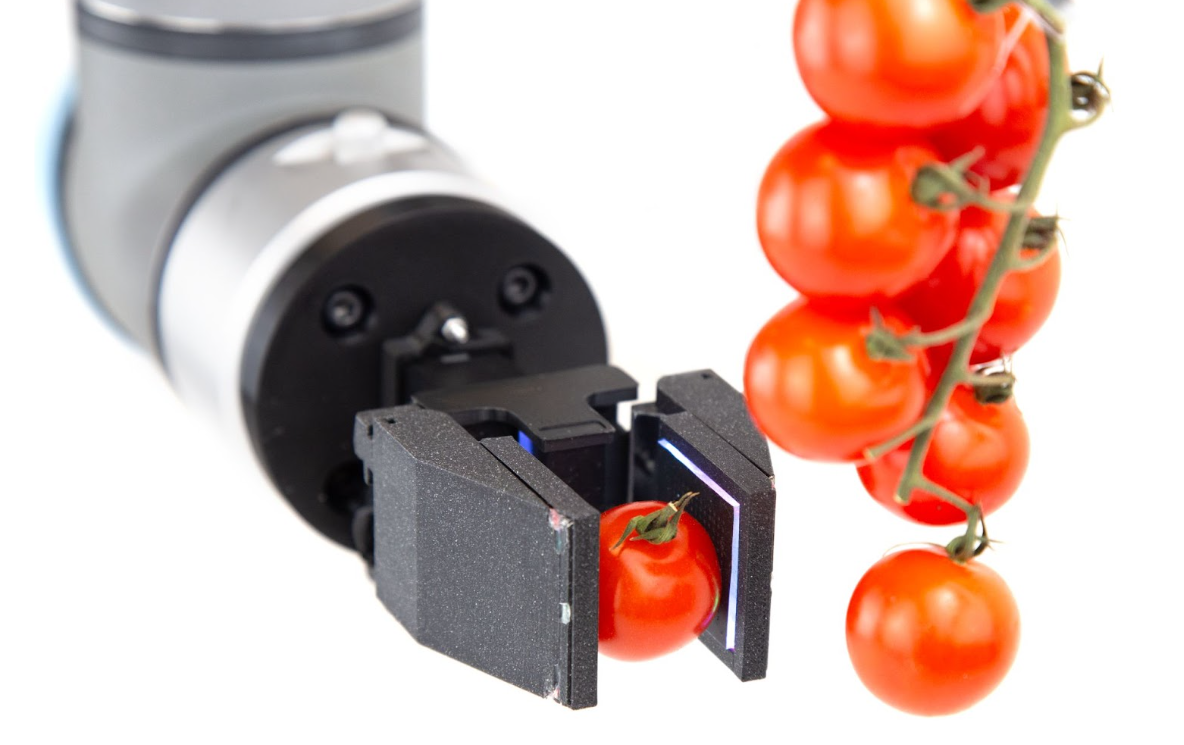
We propose FruitTouch, a compact gripper that integrates high-resolution, vision-based tactile sensing to enable gentle, scalable fruit harvesting with real-time force, slip, and softness estimation.
Recommended citation: Ruohan Zhang, Mohammad Amin Mirzaee, Wenzhen Yuan. (2026). "FruitTouch: A Perceptive Gripper for Gentle and Scalable Fruit Harvesting." IEEE Robotics and Automation Letters (RA-L).